Mobile manipulation
Two arms on a wheeled base, with lift, head and base control in ROS 2.
The problem
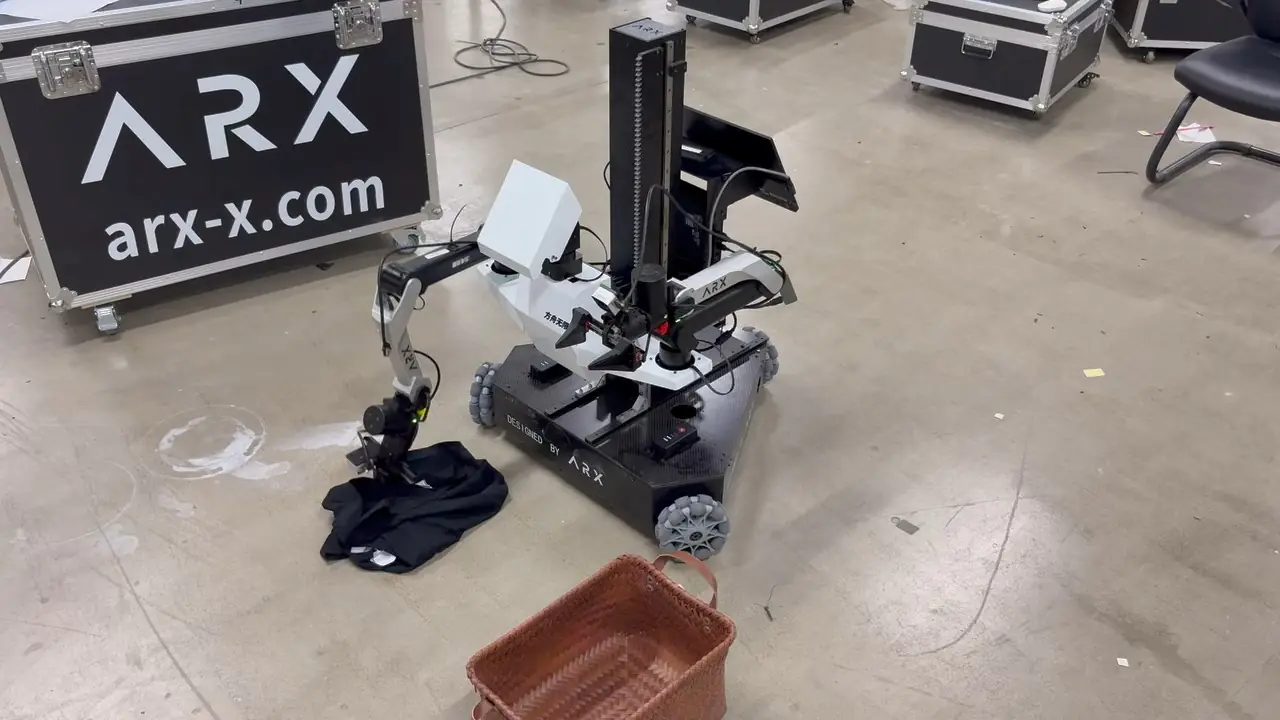
Household and lab tasks happen across a room and at different heights. A mobile platform needs a base you can drive from code, a lift to change working height and a head camera that can look where the hands are.
How it works
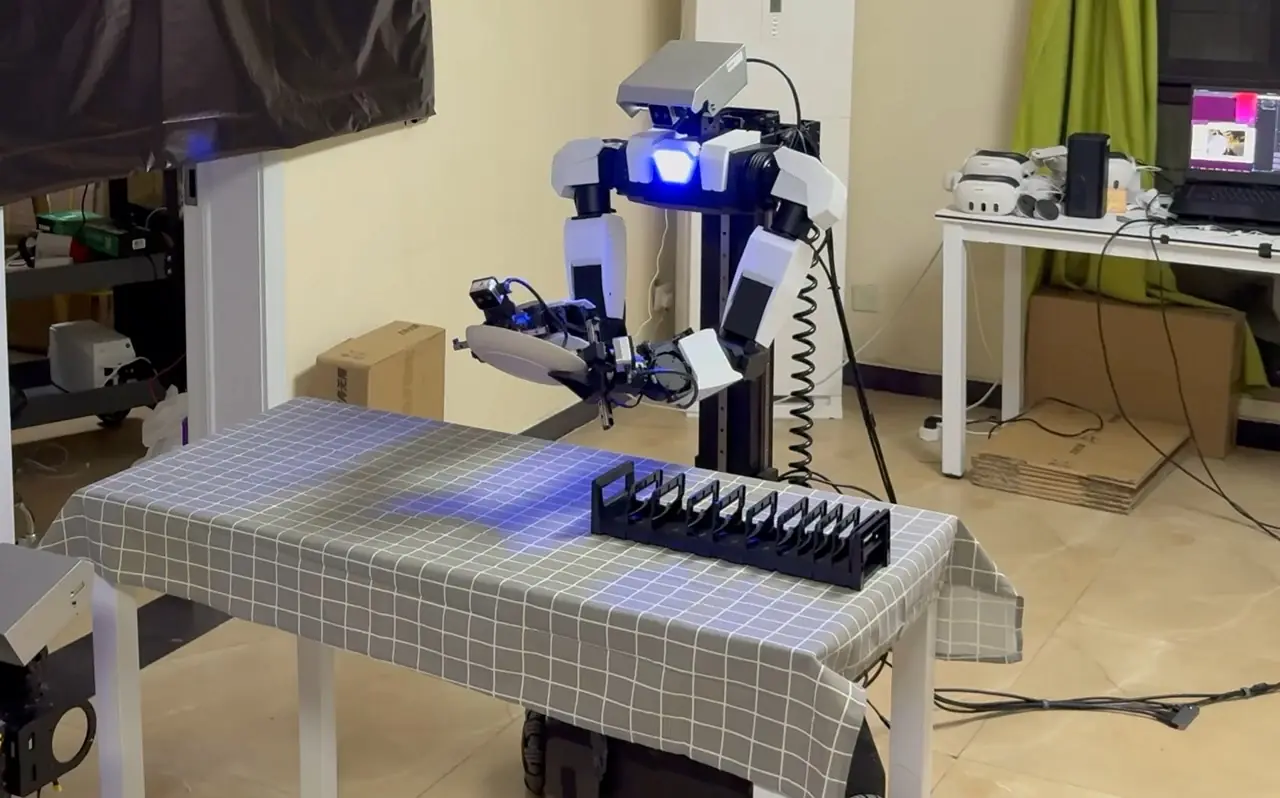
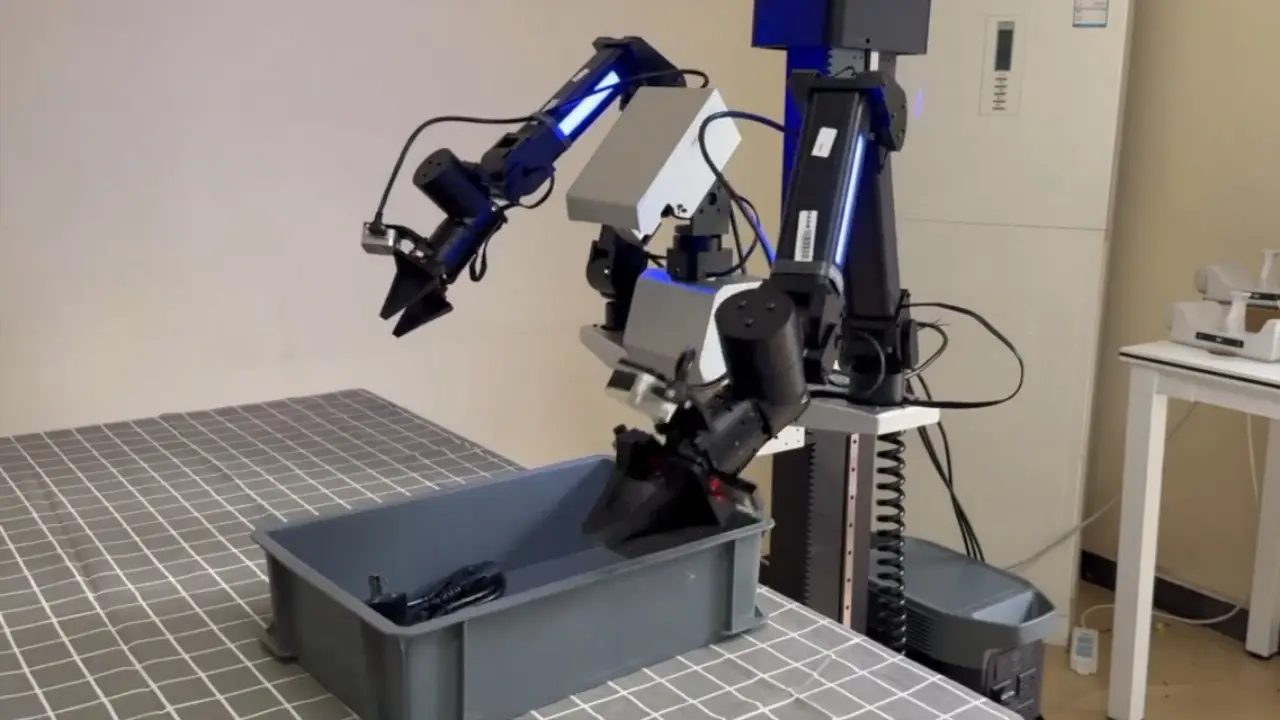
- 01Teleoperate in VR or with leader arms.
- 02Fix the lift height while recording if the task needs it.
- 03Drive the base through /body_control and read /body_information.
- 04Train and deploy with ARX's ROS 2 pipeline.
Evidence
Public sources only. All research
- ARX's collect–train–deploy pipeline supports LIFT2s and X7s.
- ModPack (Stanford, 2026) uses ARX5 leader arms for a mobile manipulation platform.
Questions
LIFT 2 or X7?
LIFT 2 is a dual-arm platform with a lift column; X7 has a humanoid upper body. Both run the same ROS 2 pipeline (LIFT2s, X7s).
Price this setup.
Tell us how many stations and where they ship.